Hi there  Welcome to my Homepage!
Hi! I am Zepeng Lin , A Sophomore at South China University of Technology, diving into the research of Embodied AI, especially focusing on how to narrow down the sim-to-real gap and scale up simulation data for robotic learning.
Feel free to reach out if you are interested in collaboration or potential opportunities.
News
- 2026.05 🎉🎉 ECCV +1! Our paper CoCo was accepted to ECCV 2026.
- 2025.11 🎉🎉 I won the first prise in The Chinese Mathematics Competitions for College Students (Top 6%).
- 2025.05 🎉🎉 I won Meritorious Winner in Mathematical Contest in Modeling (Top 6%).
- 2024.09 🎉🎉 I began my studies at SCUT.
Research Experience

HKUST
2026.07 - Present
Robotic Learning Intern cooperate with Wengxuan Song
Main contribution: Responsible for generating large-scale robot memory datasets and contributing to the pretraining of robotic memory capabilities. Also led the design of a benchmark to evaluate the error-recovery capabilities of Vision-Language-Action (VLA) models in mobile manipulation tasks.
2026.07 - Present
Robotic Learning Intern cooperate with Wengxuan Song
Main contribution: Responsible for generating large-scale robot memory datasets and contributing to the pretraining of robotic memory capabilities. Also led the design of a benchmark to evaluate the error-recovery capabilities of Vision-Language-Action (VLA) models in mobile manipulation tasks.

Peking University
2026.03 - 2026.07
Robotic Learning Intern cooperate with Yue Chen
Main contribution: teaching hotpot robots to understand human emotions.
2026.03 - 2026.07
Robotic Learning Intern cooperate with Yue Chen
Main contribution: teaching hotpot robots to understand human emotions.

South China University of Technology
2025.04 - 2026.03
Robotic Learning Intern advised by Huiping Zhuang
Research on Embodied AI and robotic learning.
2025.04 - 2026.03
Robotic Learning Intern advised by Huiping Zhuang
Research on Embodied AI and robotic learning.
Industry Experience

Lightwheel AI
2026.03 - 2026.07
Robotic Learning Intern cooperate with Yue Chen
Main contribution: Responsible for building the simulation infra and training mobile operation end-to-end VLA.
2026.03 - 2026.07
Robotic Learning Intern cooperate with Yue Chen
Main contribution: Responsible for building the simulation infra and training mobile operation end-to-end VLA.
Publications
Stable World: Reinforcement Learning for Action-Conditioned World Model for Stable Embodied Simulation
Haobo Li, Yanhong Zeng, Zeyu Lou, ZePeng Lin, Haoran Qian, Qin Zhao, Zhihao Xie, Zipeng Zhang.
An action-conditioned world model trained with reinforcement learning to keep embodied simulation stable.
ICLR 2027 (In Submission)
Haobo Li, Yanhong Zeng, Zeyu Lou, ZePeng Lin, Haoran Qian, Qin Zhao, Zhihao Xie, Zipeng Zhang.
An action-conditioned world model trained with reinforcement learning to keep embodied simulation stable.
ICLR 2027 (In Submission)
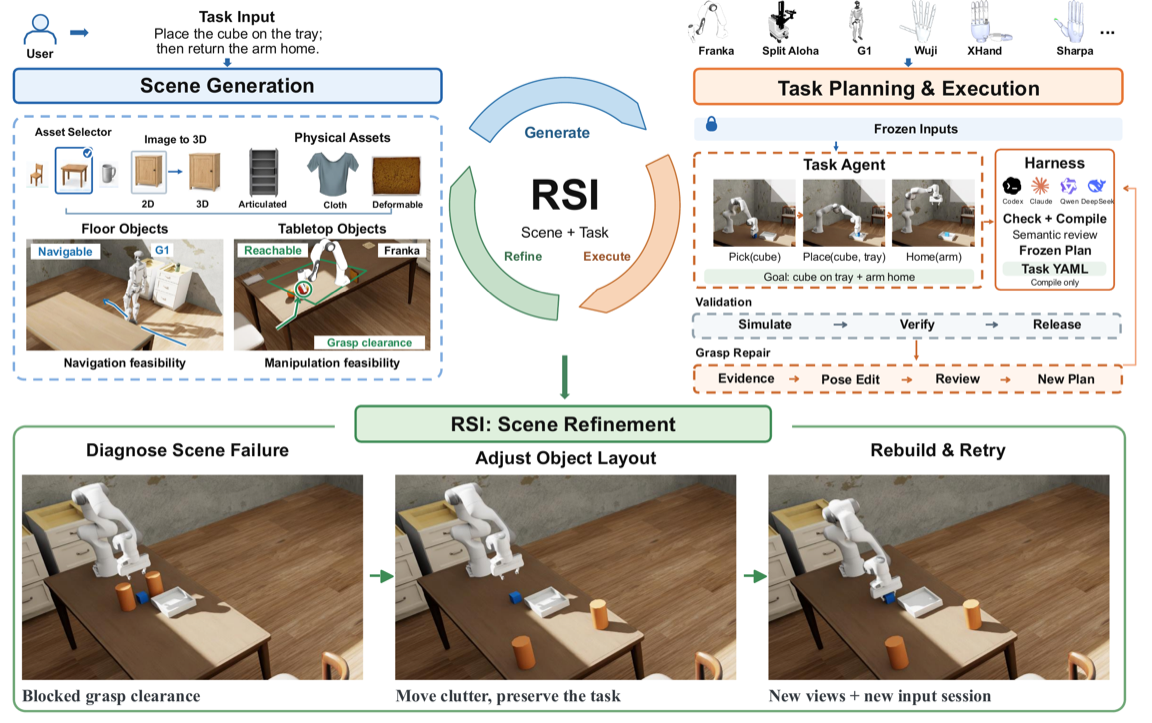
EmbodiedSmith: Scaling Embodied Data through Recursive Self-Improvement Flywheel in Simulation
Yikai Qin, Mingji Liang, Yifei Deng, Wenxuan Song, ZePeng Lin, Zhiyi Jiang, Jiajun Fu, Qiao Sun, Huashuo Lei, Xicheng Gong, Jiayi Chen, Han Zhao, Shuanghao Bai, Pengxiang Ding, Pengwei Wang, Haorang Li.
A recursive self-improvement flywheel that scales embodied data generation in simulation.
ICLR 2027 (In Submission)
Yikai Qin, Mingji Liang, Yifei Deng, Wenxuan Song, ZePeng Lin, Zhiyi Jiang, Jiajun Fu, Qiao Sun, Huashuo Lei, Xicheng Gong, Jiayi Chen, Han Zhao, Shuanghao Bai, Pengxiang Ding, Pengwei Wang, Haorang Li.
A recursive self-improvement flywheel that scales embodied data generation in simulation.
ICLR 2027 (In Submission)
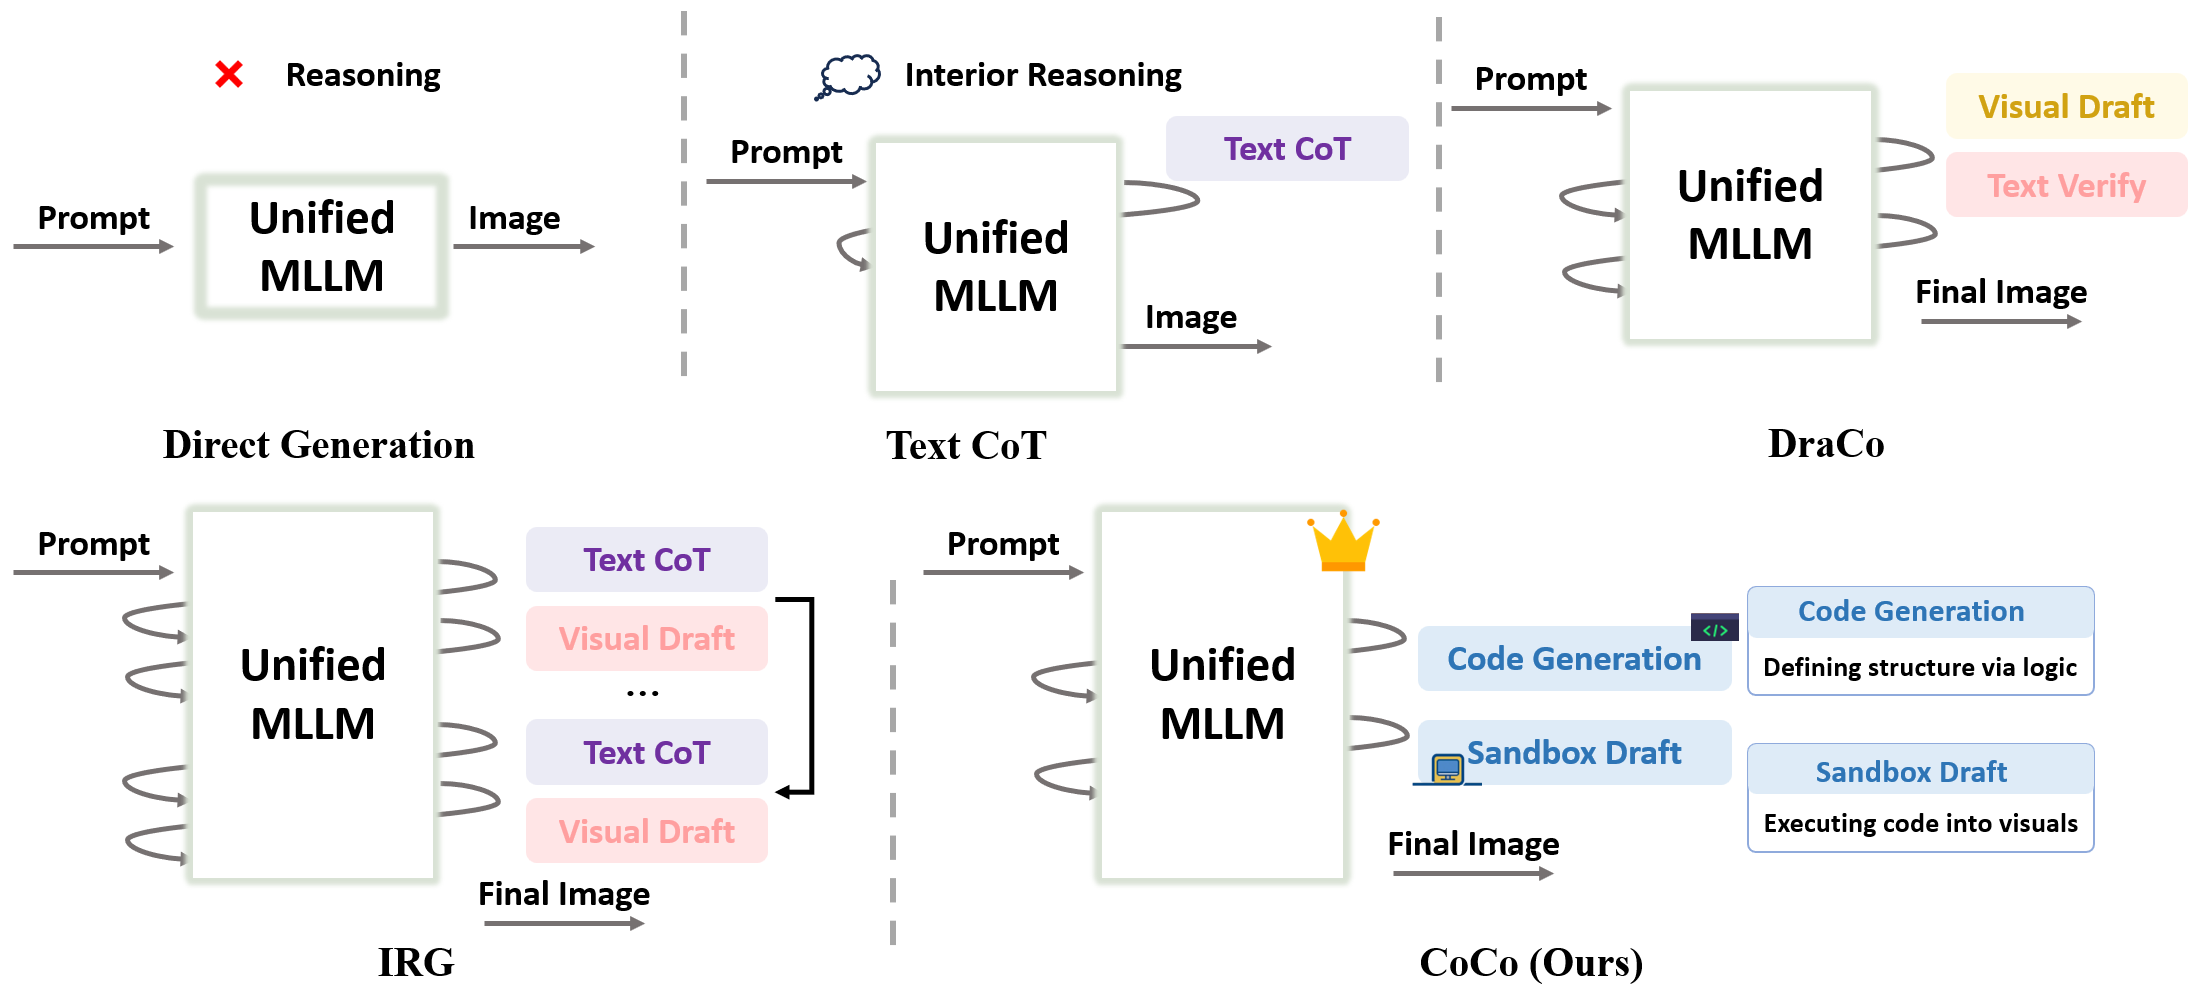
CoCo: Code as CoT for Text-to-Image Preview and Rare Concept Generation
Haodong Li, Chunmei Qing, Huanyu Zhang, Dongzhi Jiang, Yihang Zou, Hongbo Peng, Dingming Li, Yuhong Dai, ZePeng Lin, Juanxi Tian, Yi Zhou, Siqi Dai, Jingwei Wu, Pheng-Ann Heng.
We propose a code-driven reasoning framework that renders executable scene layouts as deterministic visual drafts before refining them into high-fidelity text-to-image results. We also introduce CoCo-10K for learning structured draft-to-final image refinement.
ECCV 2026 (Accepted) [arXiv] [PDF]
Haodong Li, Chunmei Qing, Huanyu Zhang, Dongzhi Jiang, Yihang Zou, Hongbo Peng, Dingming Li, Yuhong Dai, ZePeng Lin, Juanxi Tian, Yi Zhou, Siqi Dai, Jingwei Wu, Pheng-Ann Heng.
We propose a code-driven reasoning framework that renders executable scene layouts as deterministic visual drafts before refining them into high-fidelity text-to-image results. We also introduce CoCo-10K for learning structured draft-to-final image refinement.
ECCV 2026 (Accepted) [arXiv] [PDF]
Projects

AutoDataGen
Responsible for adapting curobo to different robots and generating simulation data for mobile manipulation robots, including curobo and IK adaptation for various mobile-base robots (e.g., G1, X7s) and development of corresponding adapters. Built IsaacLab gym environments and wrote environment registration code for different robots, covering three actuation modes (e.g., absolute and relative joint-angle control). Also fixed the IsaacLab platform bug where PhysX and USD misalignment caused curobo collision-avoidance failures.
Project [code]
Responsible for adapting curobo to different robots and generating simulation data for mobile manipulation robots, including curobo and IK adaptation for various mobile-base robots (e.g., G1, X7s) and development of corresponding adapters. Built IsaacLab gym environments and wrote environment registration code for different robots, covering three actuation modes (e.g., absolute and relative joint-angle control). Also fixed the IsaacLab platform bug where PhysX and USD misalignment caused curobo collision-avoidance failures.
Project [code]
GraphRL-Fleet
Zepeng Lin, Guanyu Xin, Yuxuan Xue.
A research-oriented repository for dynamic scheduling of new energy logistics fleets, featuring a graph-based simulation engine, Guangzhou Panyu district real road-network data, online heuristic and Q-learning policies, an offline MILP baseline, a FastAPI backend, and a web visualization frontend.
Project [code]
Zepeng Lin, Guanyu Xin, Yuxuan Xue.
A research-oriented repository for dynamic scheduling of new energy logistics fleets, featuring a graph-based simulation engine, Guangzhou Panyu district real road-network data, online heuristic and Q-learning policies, an offline MILP baseline, a FastAPI backend, and a web visualization frontend.
Project [code]

HW4openclass
Zepeng Lin.
Summary of answers to publicly available foreign courses that have been studied.
Project [code]
Zepeng Lin.
Summary of answers to publicly available foreign courses that have been studied.
Project [code]
Awards
- 2025.11, The first prise in The Chinese Mathematics Competitions for College Students (Top 6%).
- 2025.05, Meritorious Winner in Mathematical Contest in Modeling (Top 6%).